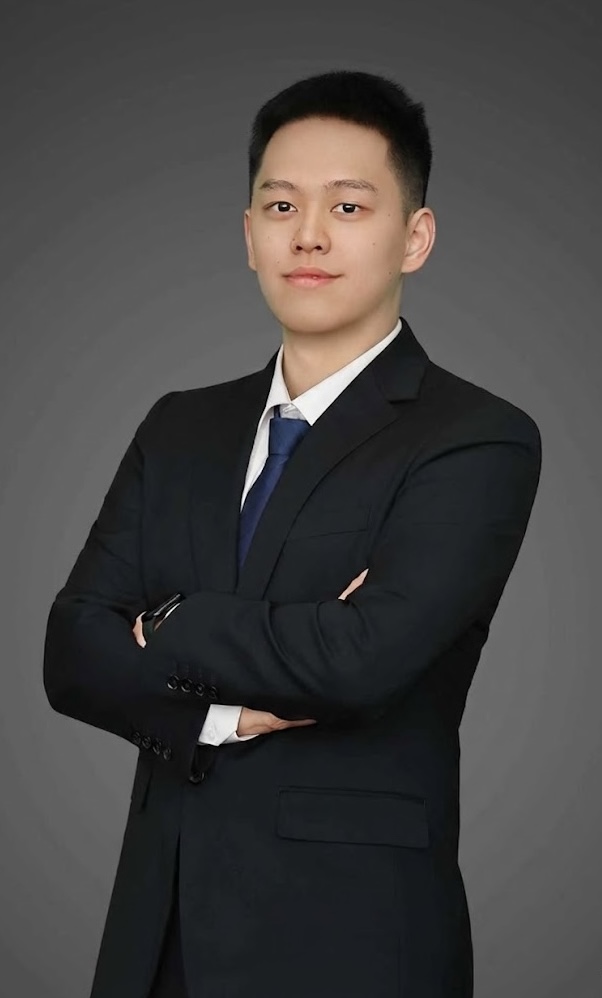
Junkai Tan谭浚楷
HKPFS Ph.D. Fellow PolyU AAE
About
I am an HKPFS Ph.D. Fellow in the Department of Aeronautical and Aviation Engineering at The Hong Kong Polytechnic University (PolyU), advised by Prof. Wen-Hua Chen and affiliated with RCLAE.
Current work
I am exploring how Prof. Chen’s dual control for exploration and exploitation (DCEE) connects with active inference, studying how robots gather useful information while pursuing a task. My longer-term interests are world models and the links between autonomous control and cognitive neuroscience.
Recent Highlights
News archivePolicy–safety separation under polygonal constraints: accepted by SCTS.
Stackelberg attack–defense control: accepted by IEEE/CAA JAS as a regular paper.
Resilient critic-learning control: available in IEEE TII Early Access.
XJTU Graduate with Honor (2025–2026).
Best Student Paper Award, IEEE ICAIS & ISAS · XJTU Qihang Role Model Nominee.
Selected Research
Earlier work
Safe reinforcement learning, prescribed-time control, and differential games, with applications to UAV–UGV coordination and human–UAV interaction.
-
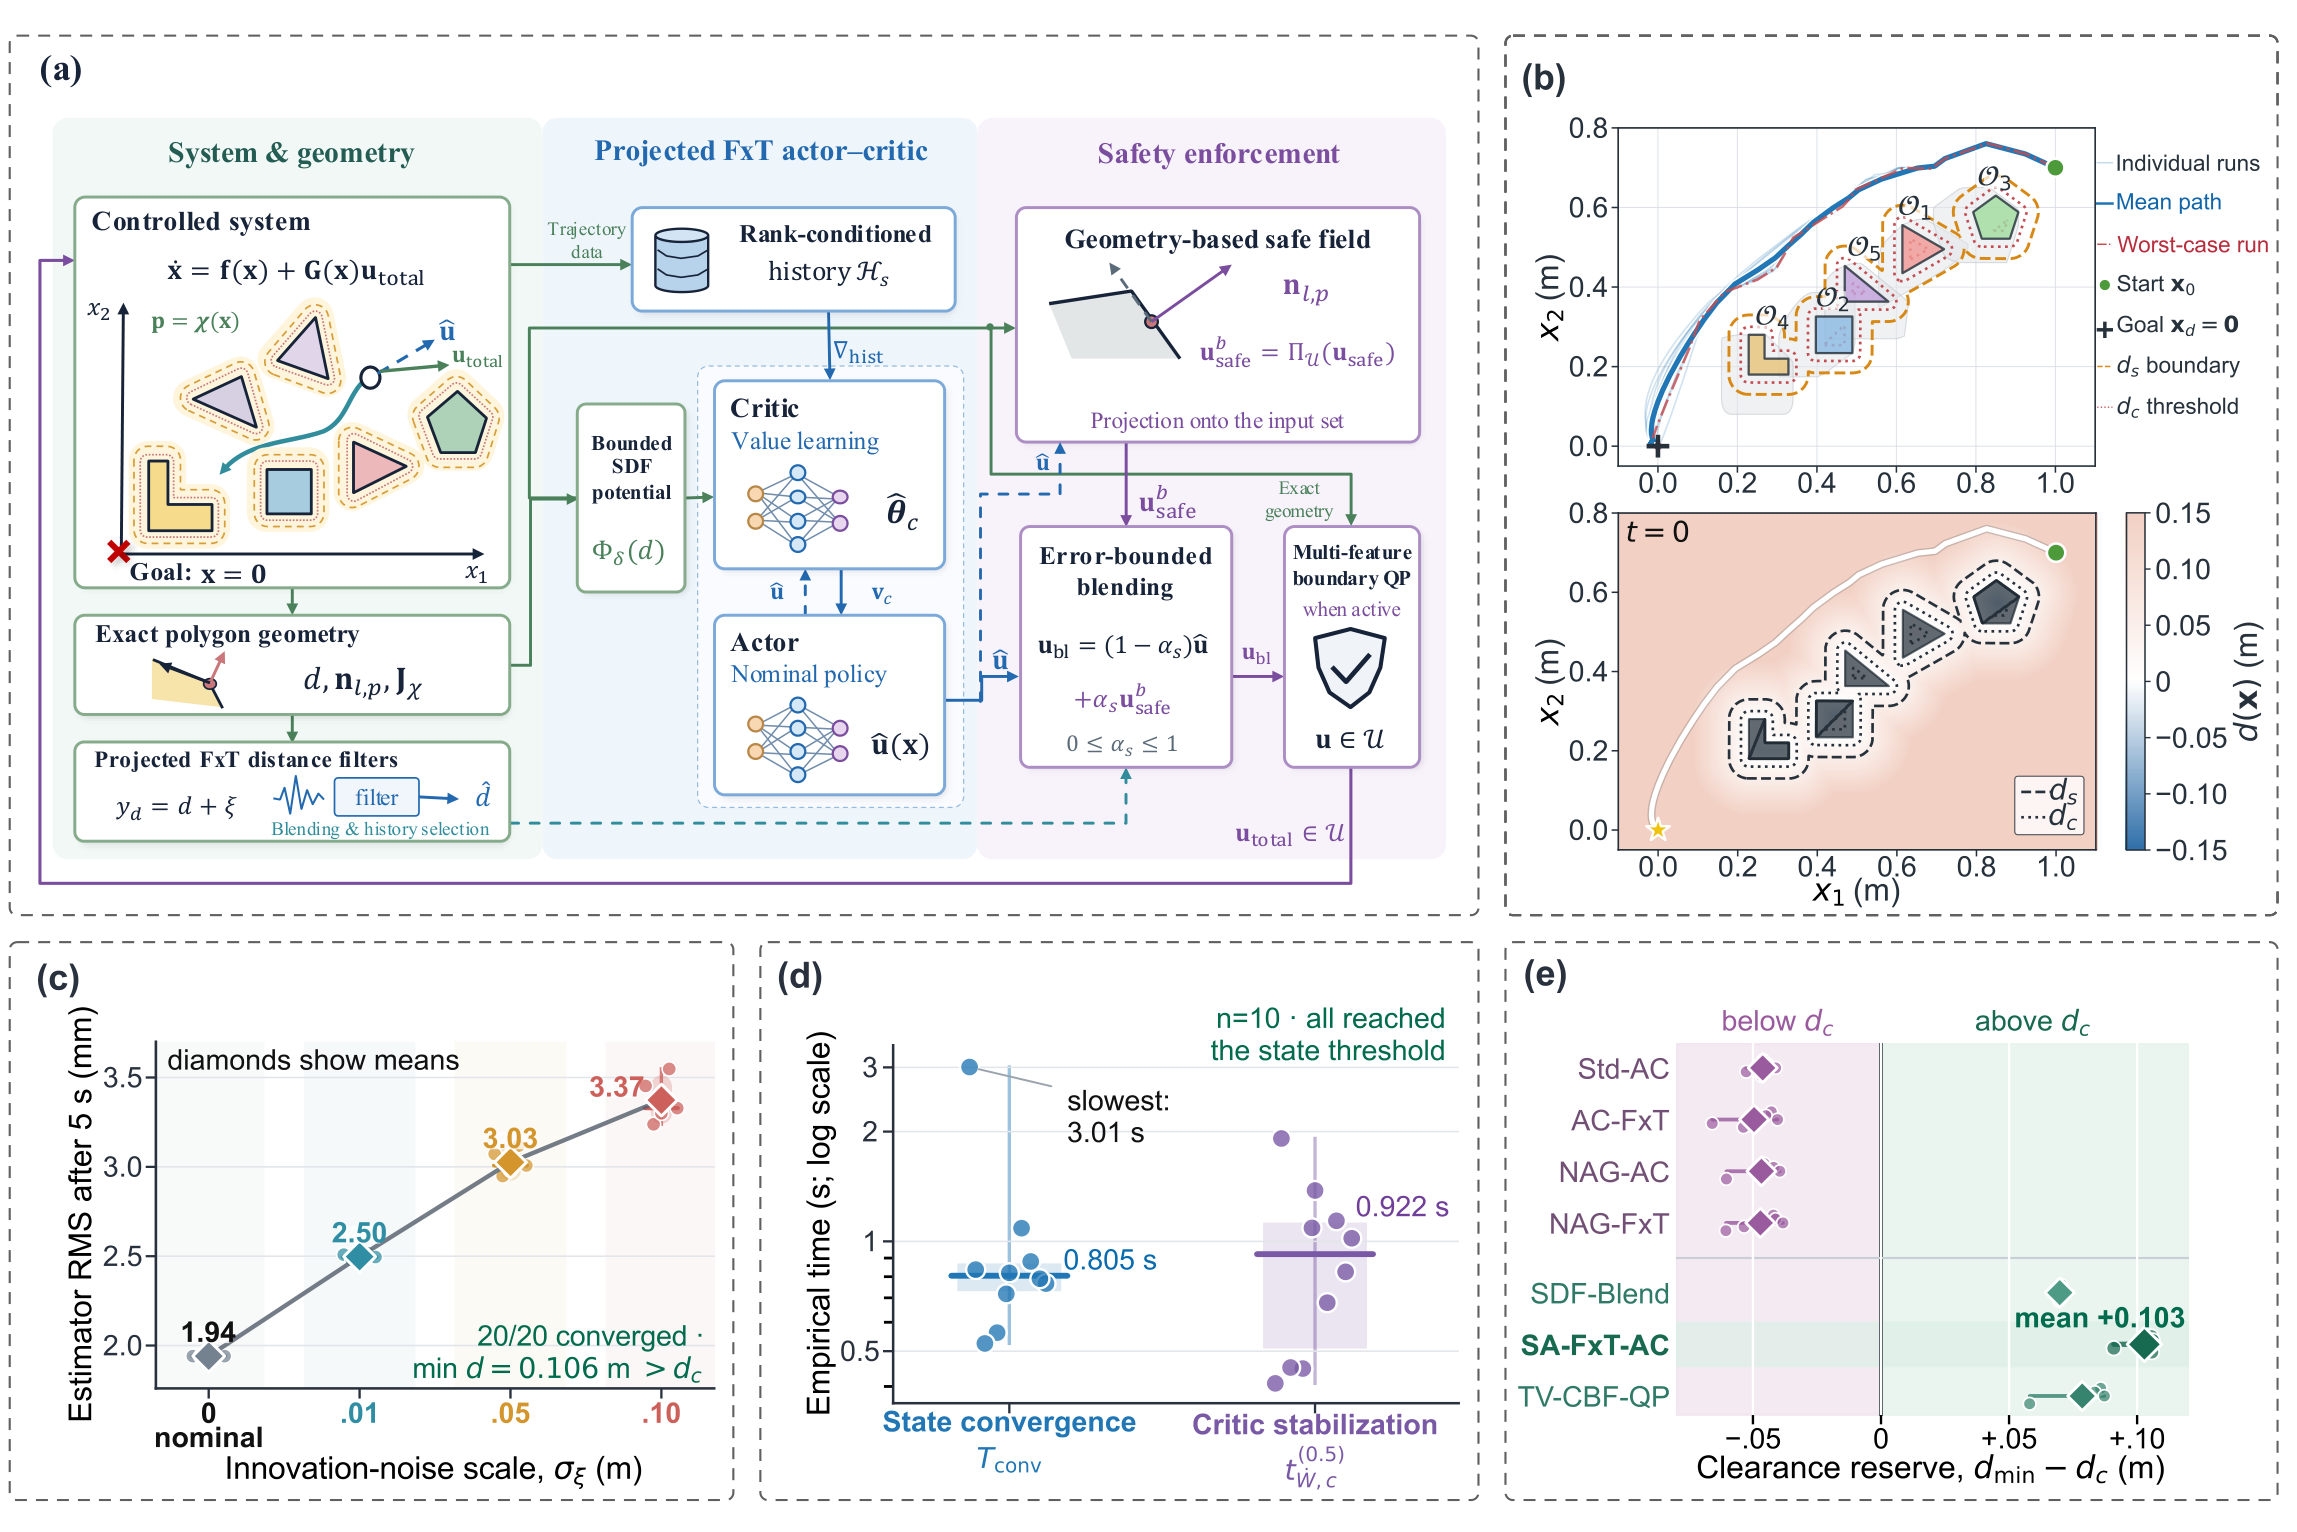
Separating control policy learning from safety enforcement under polygonal constraints
Science China Technological Sciences, 2026.
-
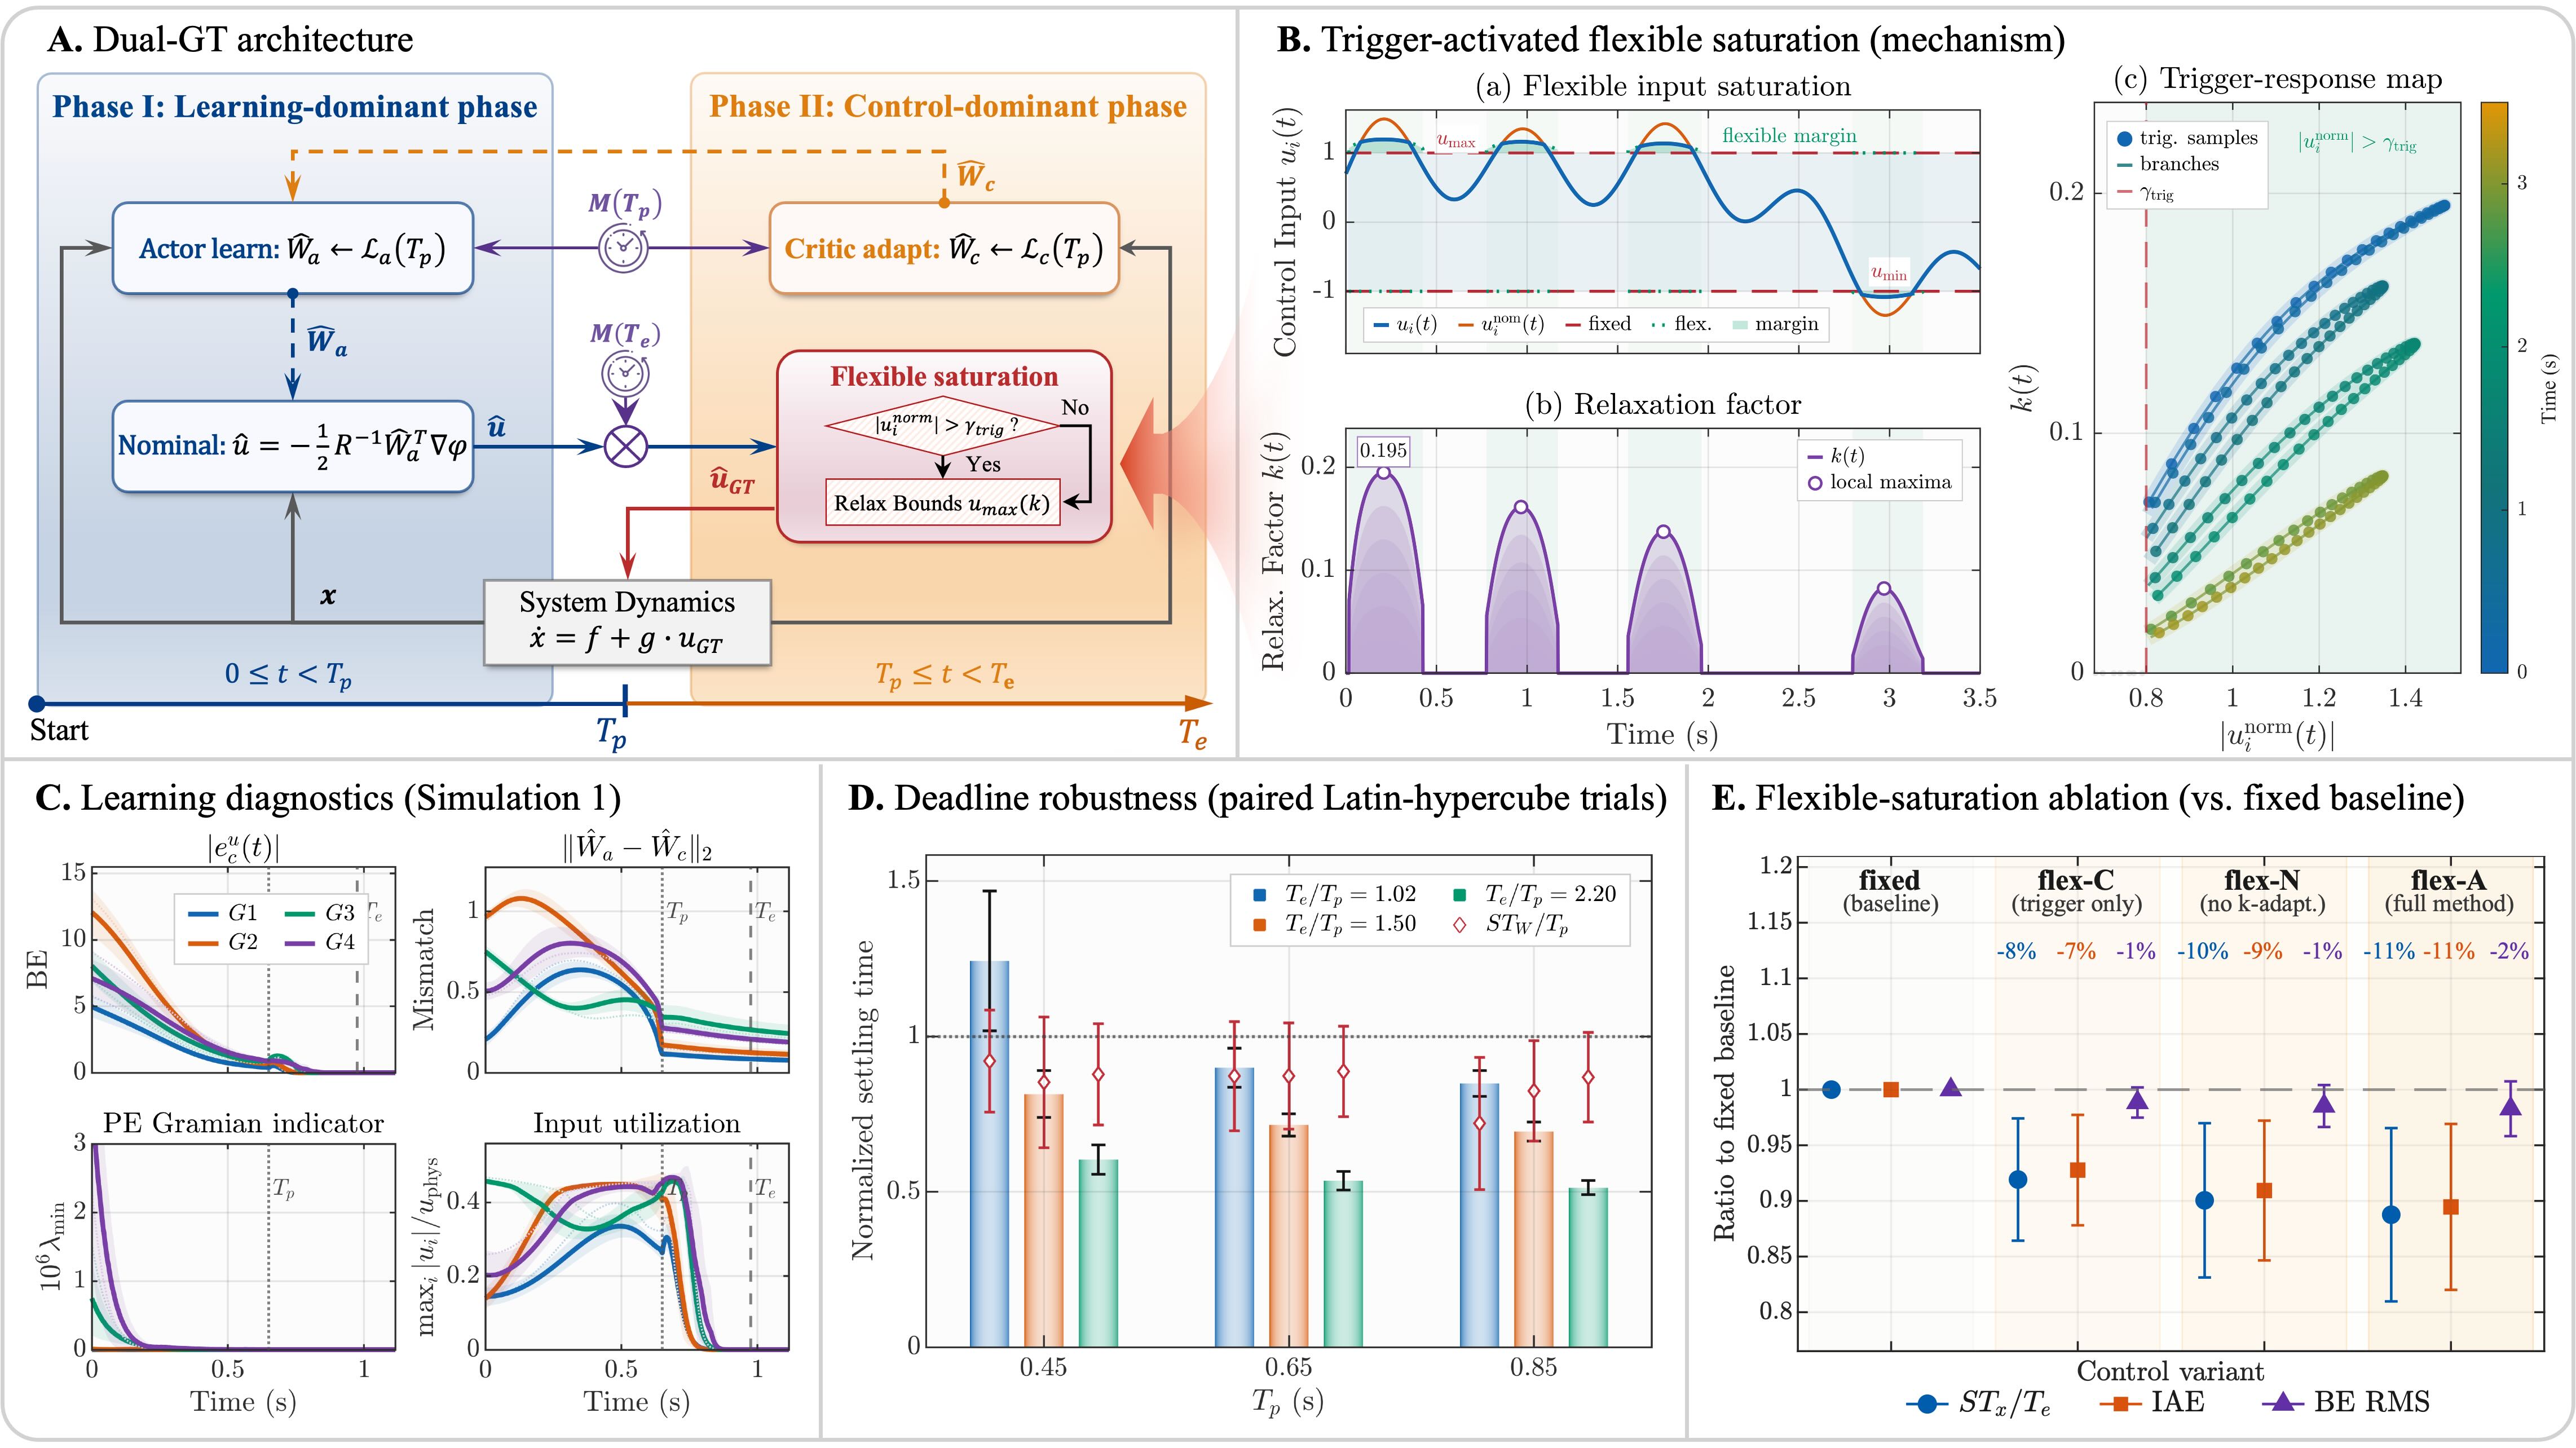
Dual-Clock Guaranteed-Time Actor-Critic Optimal Control with Flexible Input Saturation
IEEE Transactions on Systems, Man, and Cybernetics: Systems, Early Access, pp. 1–14, 2026. IEEE Xplore
-
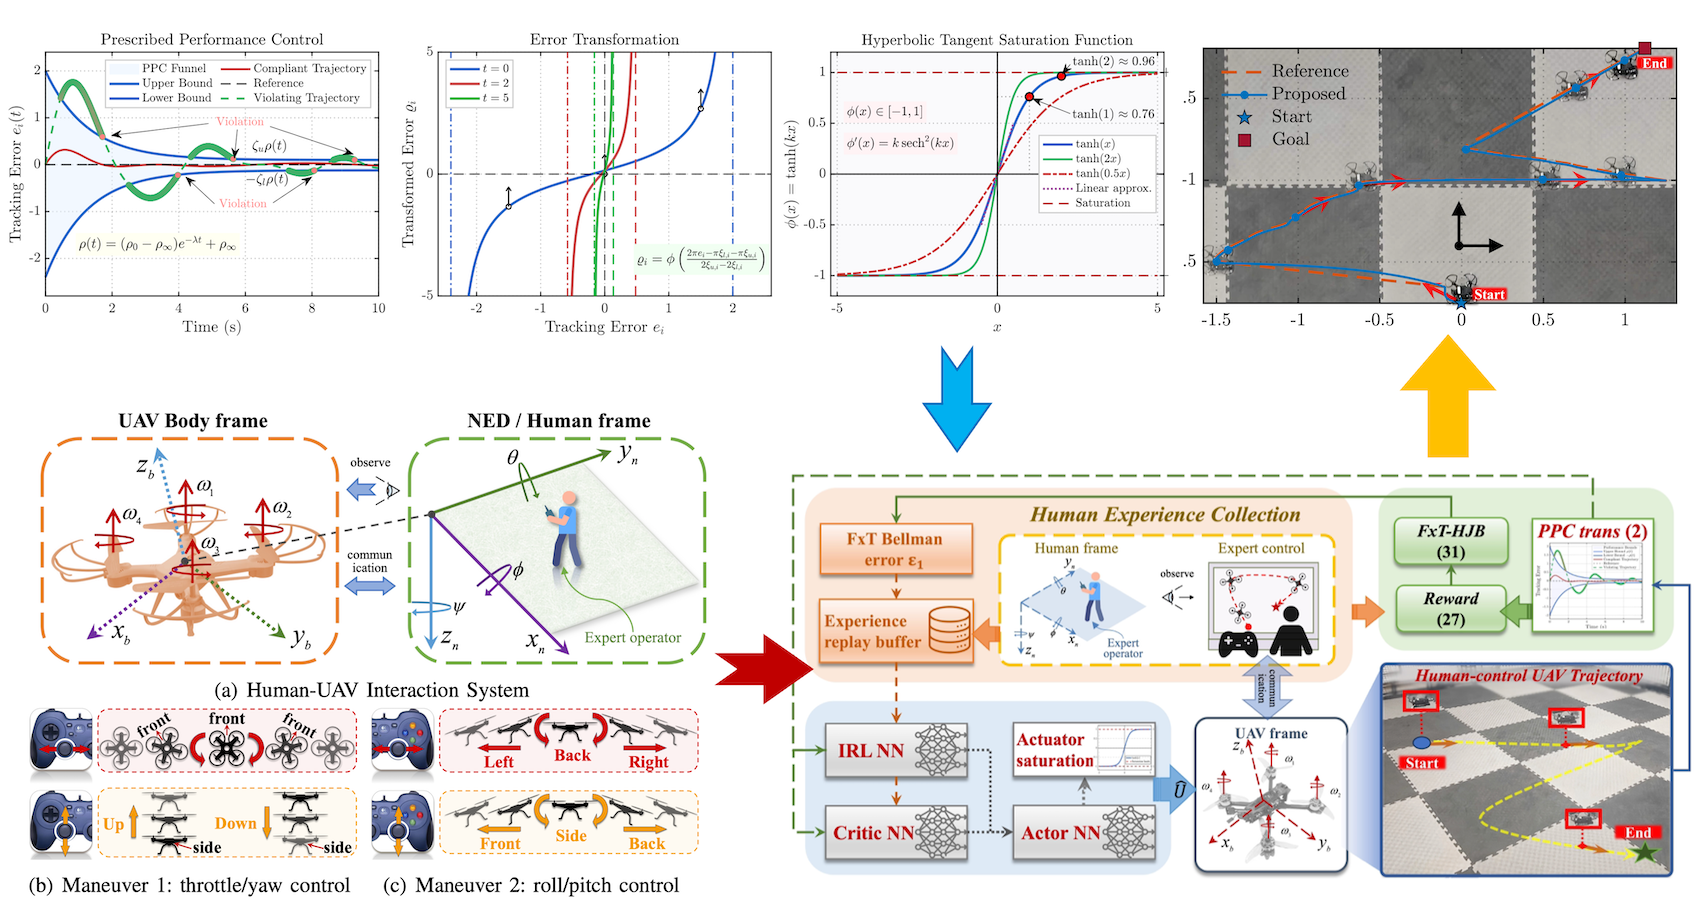
Fixed-time stochastic learning from human-UAV interaction with state-input constraints
IEEE Transactions on Industrial Electronics, 73(2): 3071–3082, 2026. IEEE Xplore
-
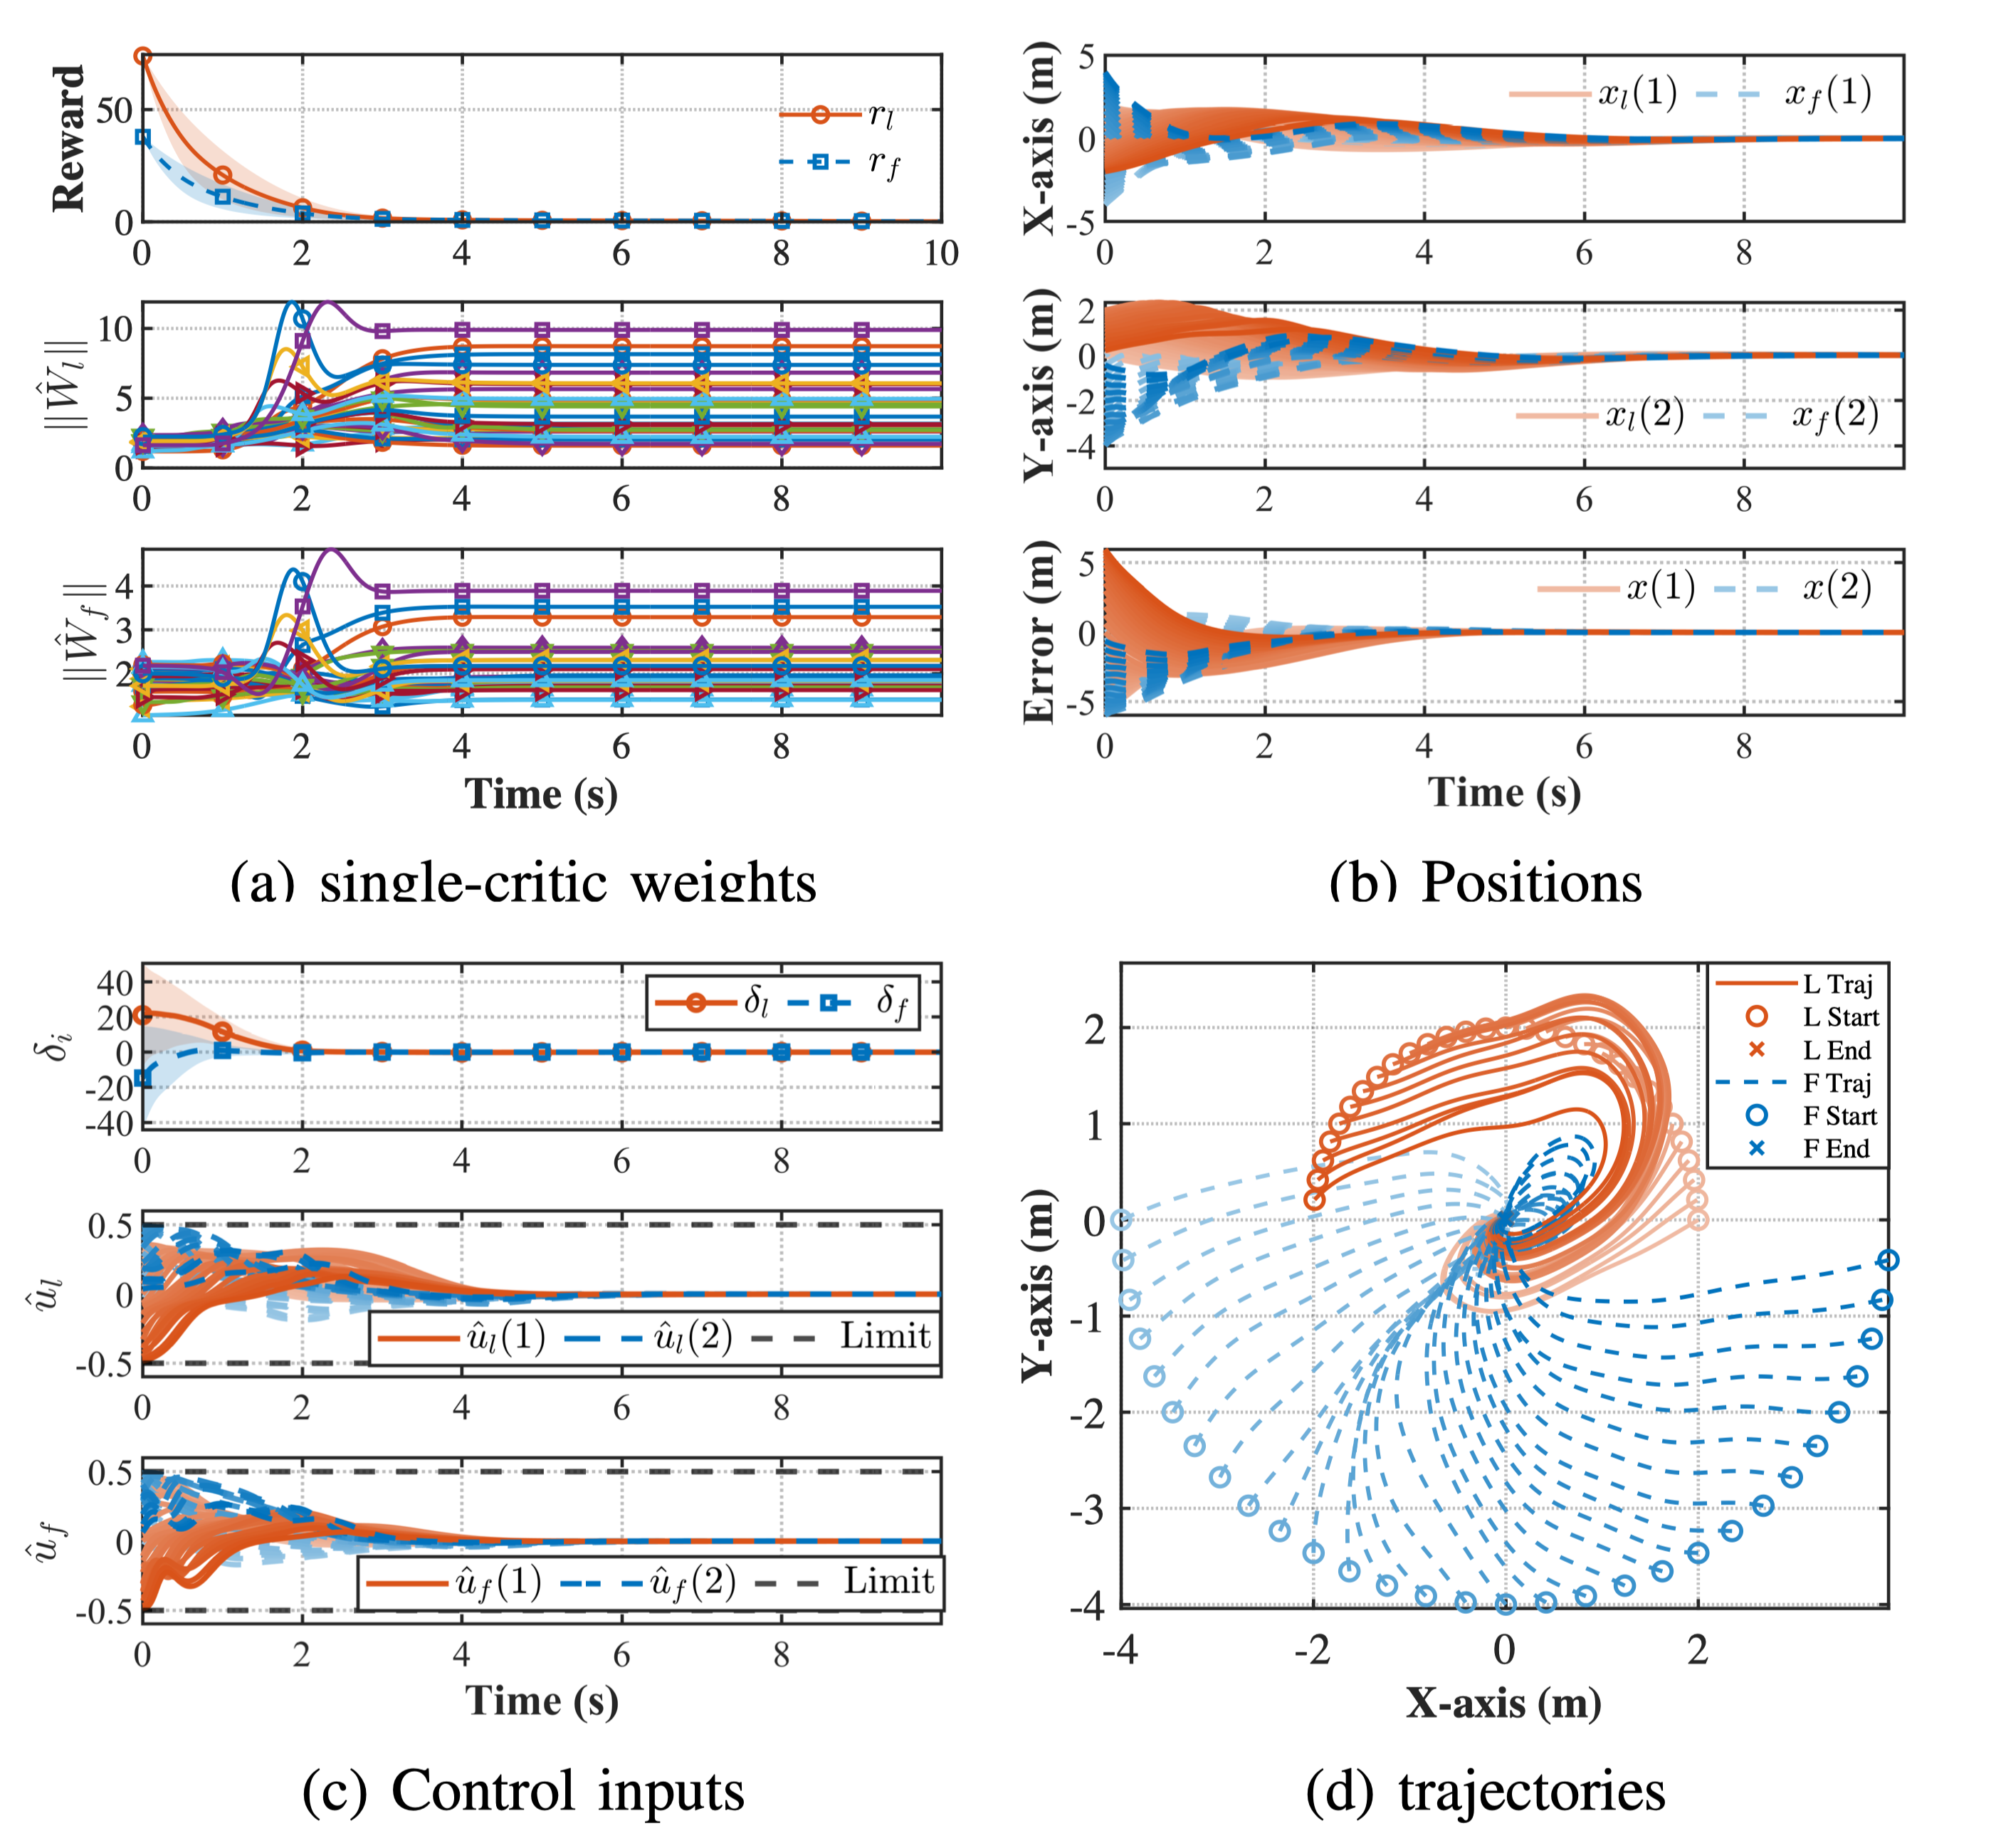
Fixed-time hierarchical game-based unmanned aerial-ground vehicle docking control
IEEE/CAA Journal of Automatica Sinica, 13(5): 1242–1244, 2026. IEEE Xplore
-
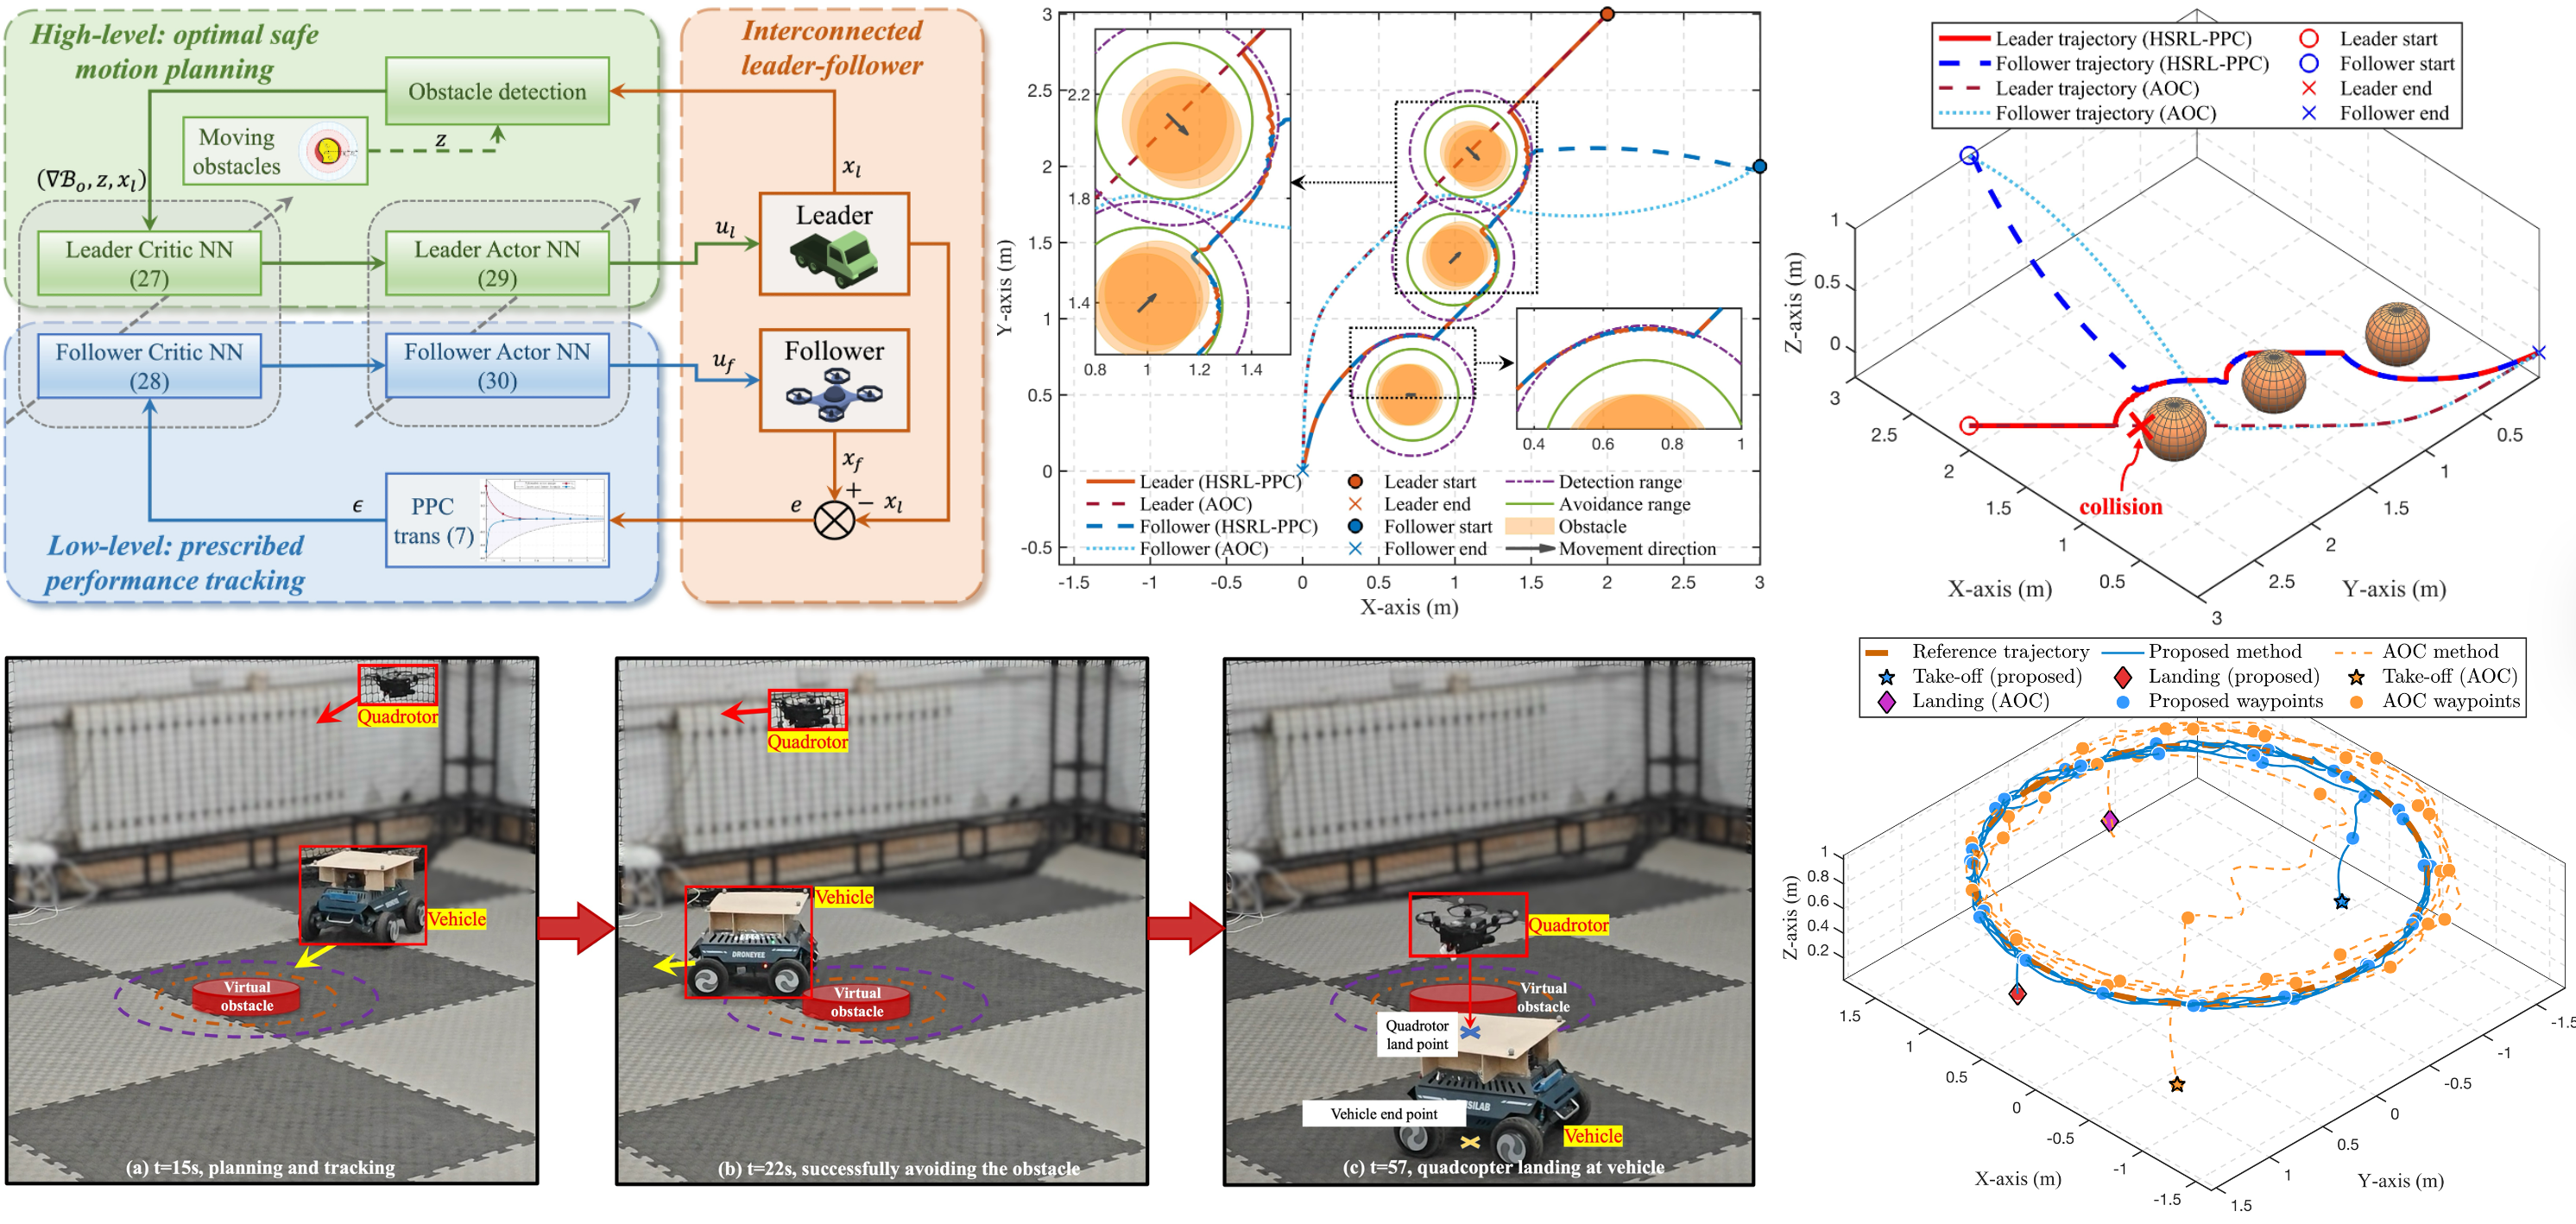
Hierarchical safe reinforcement learning control for leader-follower systems with prescribed performance
IEEE Transactions on Automation Science and Engineering, 22: 19568–19581, 2025. IEEE Xplore
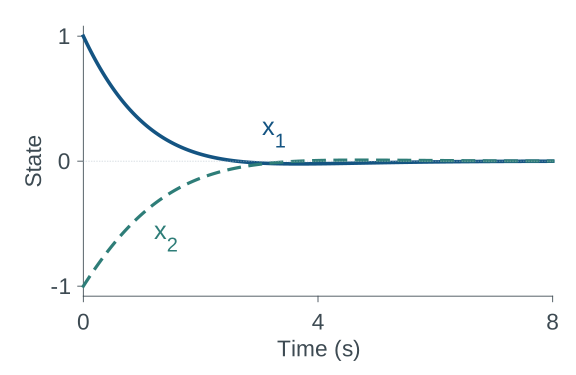
ADP-MATLAB
From equations to closed-loop experiments.
8 runnable examples MIT License
Education
- 2026 – present
- Ph.D. student, Aeronautical and Aviation EngineeringThe Hong Kong Polytechnic UniversityAdvisor: Prof. Wen-Hua ChenHKPFS & PolyU Presidential Fellowship
- 2023 – 2026
- M.E., Electrical EngineeringXi’an Jiaotong UniversityAdvisors: Prof. Hui Cao & Dr. Shuangsi XueStudent Pacesetter · National & Guodian Nanzi Special Scholarships
- 2019 – 2023
- B.E., Electrical EngineeringXi’an Jiaotong University
Academic Service
Full service record300+ peer reviews recorded on ORCID, including IEEE TAC, IEEE TCNS, IEEE TASE, IEEE TSMC: Systems, and IEEE L-CSS.
Conference reviewer, IEEE CDC · Session Chair, IEEE ICARM 2023.
Contact
Open to collaboration on safe learning, autonomous control, and low-altitude robotics.
junkai.tan@connect.polyu.hk Department of Aeronautical and Aviation EngineeringThe Hong Kong Polytechnic University
Hung Hom, Kowloon, Hong Kong Campus directions